Supervised autonomy for the physical world.
Control architectures for machines that operate in the real world — designed for supervised autonomy, with a person in the loop by design.
Control you can supervise.
Machines that move in the physical world need control architectures that are legible, bounded, and supervisable. Digi-DNA designs robotics and field systems around clear rules, hard constraints, and verification — so the operator always understands what the machine is doing and why, and can intervene.
Rules, constraints, and a human in the loop.
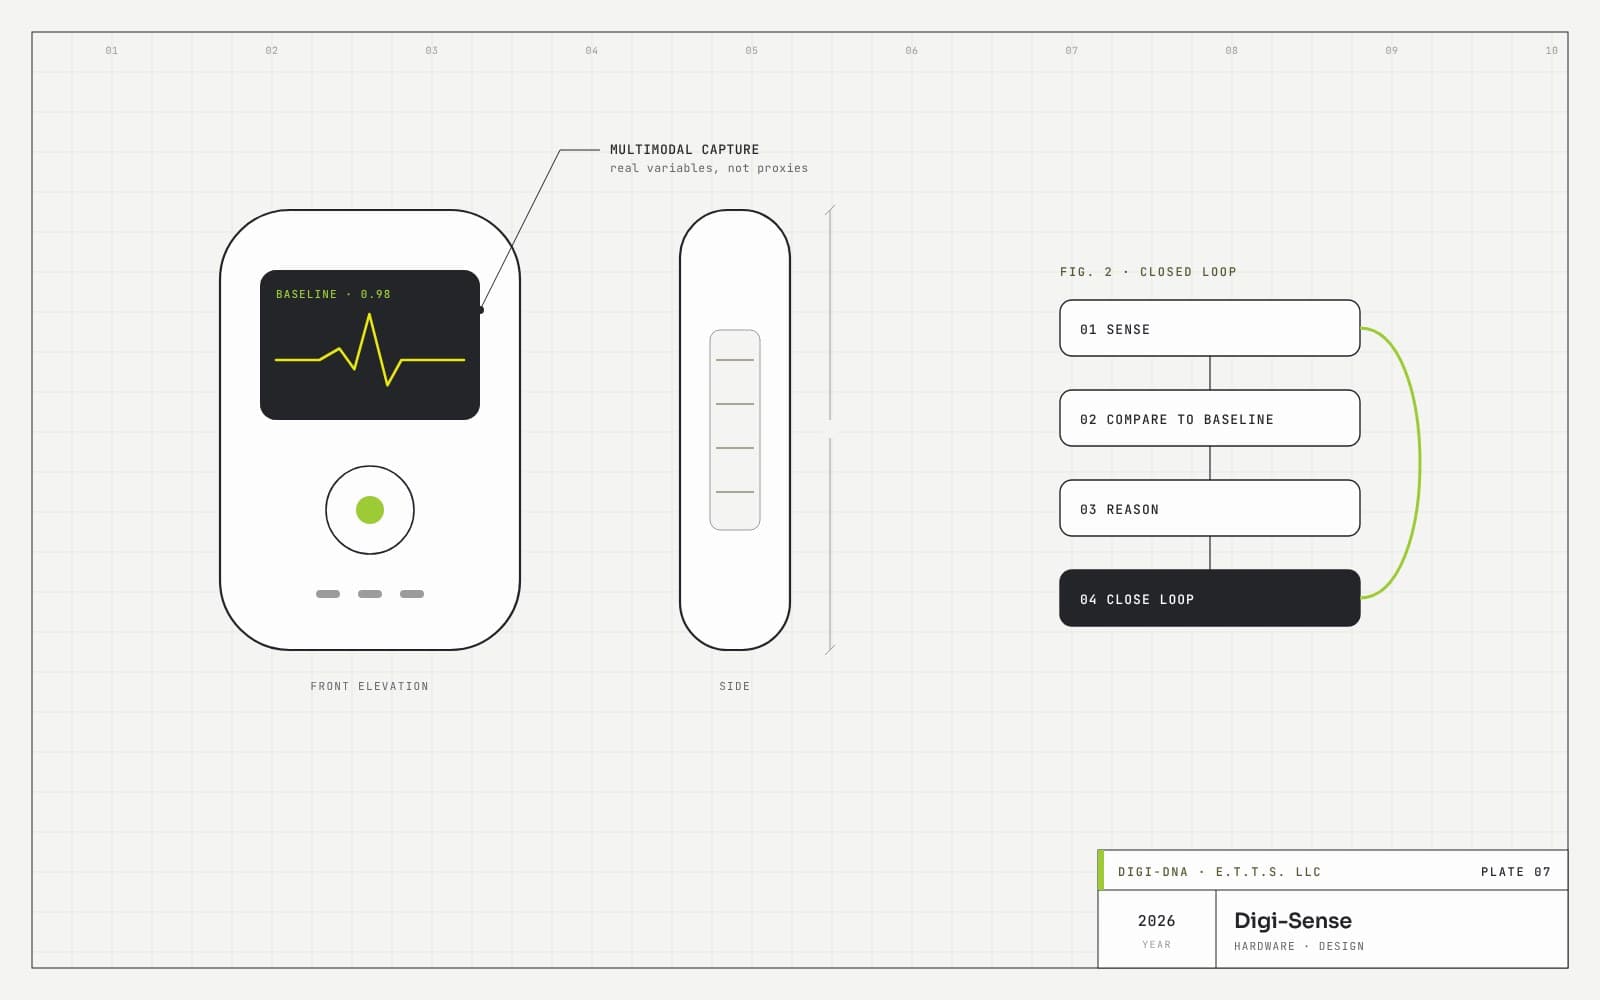
Robotics is the control layer of the model, taken to machines: actuation under encoded rules, hard constraints as safety envelopes, and verification checking every action against intent. This is supervised autonomy — capable, bounded, and accountable.
Backed by formal study.
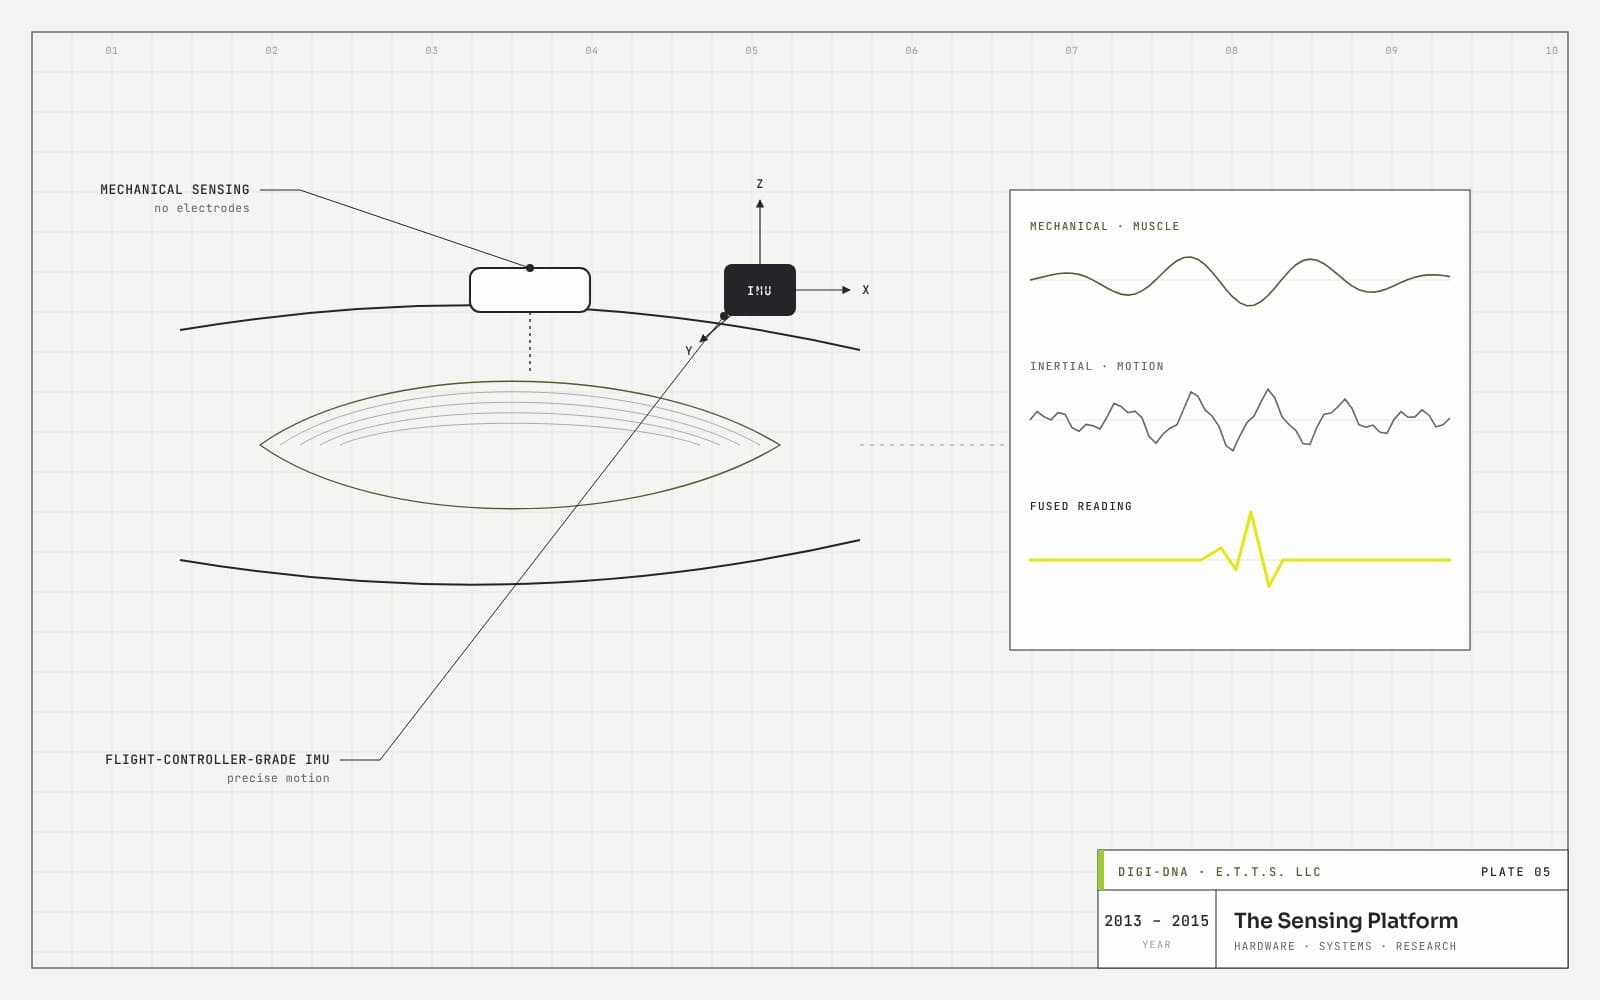
The robotics work is grounded in graduate-level coursework in underactuated robotics and autonomous flight, and in a sensing platform built to read the physical world directly.